Ph.D. researcher · University of Central Florida

Machine learning for robot control, grounded in physics.

I'm Nam Nguyen. I build dynamics models that combine physics with learning, measure how far they can be trusted, and put them inside controllers for race cars, quadrotors, and manipulators.

Open to ML and robotics internships

Nam Nguyen

Research

Model, quantify, control.

My work sits at the intersection of three things: modeling a system, measuring how far the model can be trusted, and using it to control the system.

  1. 01

    System modeling

    Learn how a system behaves from data, with physics built into the model so it holds up when data is scarce.

  2. 02

    Uncertainty quantification

    Measure how far the model can be trusted, so a controller knows when it is working outside what the model has seen.

  3. 03

    Optimal control

    Use the model to act: controllers that plan ahead, adapt online, and run on real hardware.

Selected work

All 7 papers
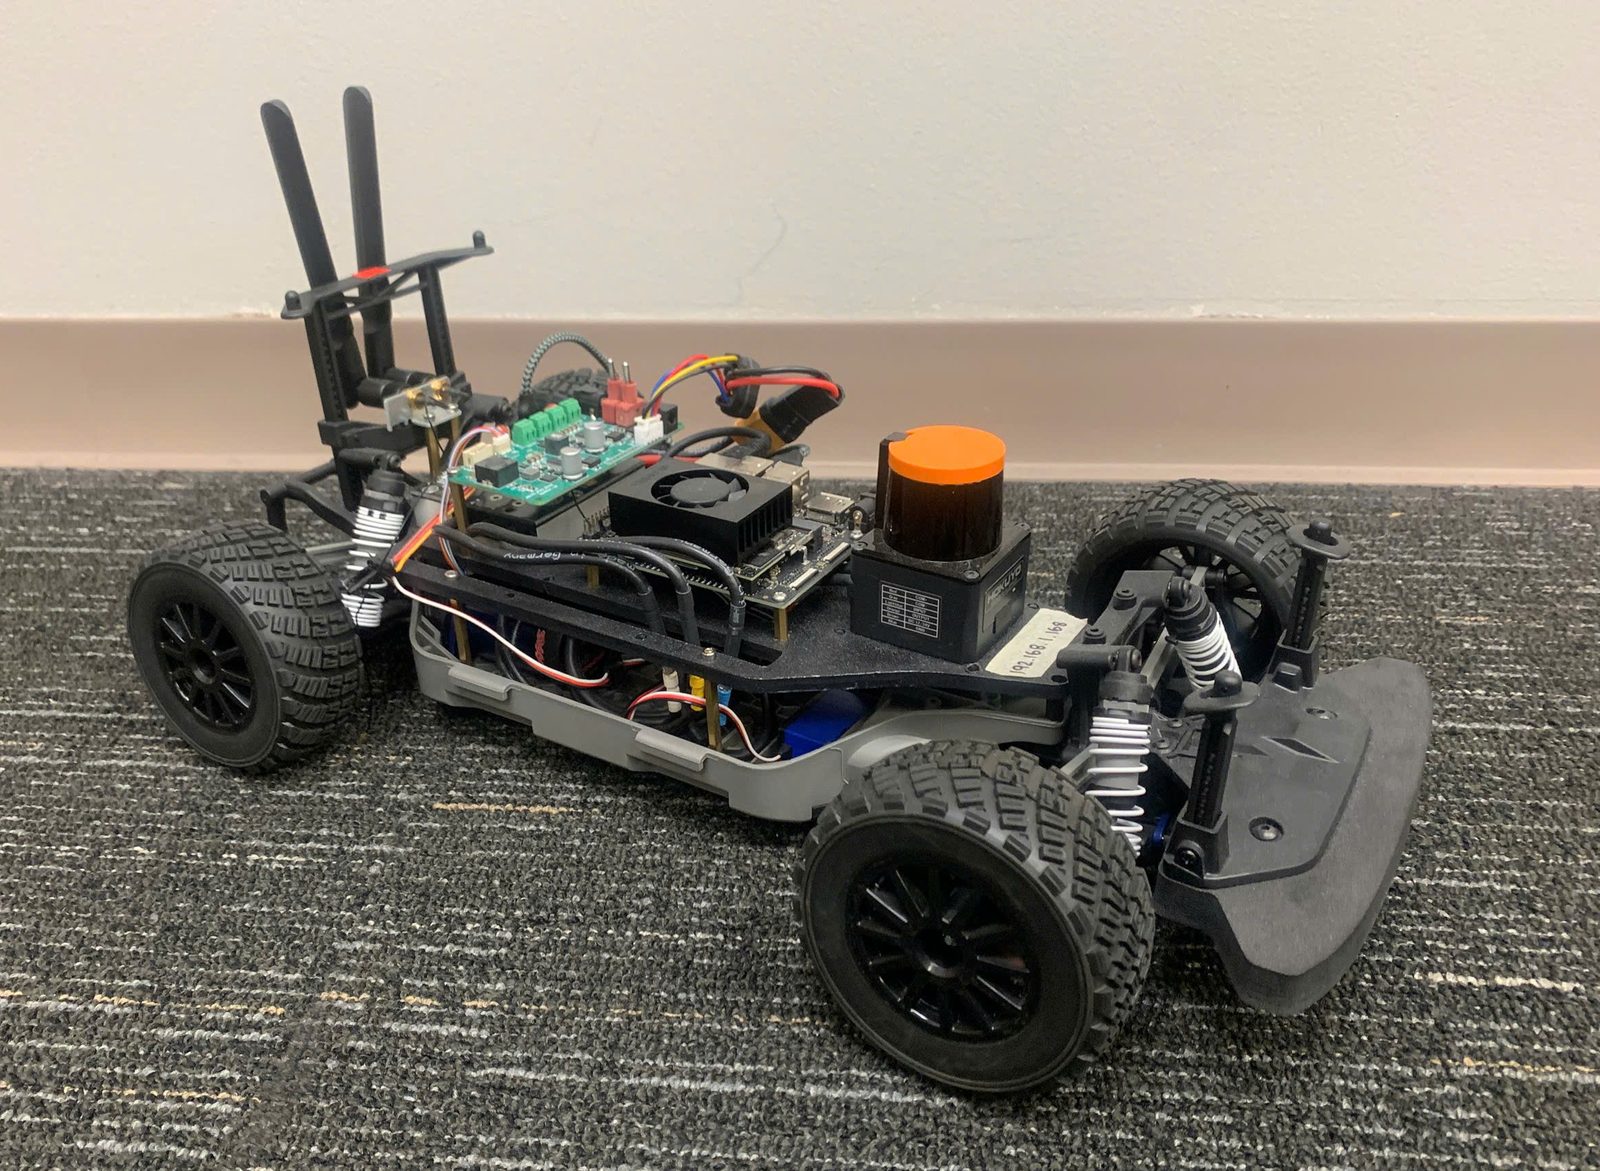
F1TENTH autonomous racing car with onboard computer and LiDAR
IROS 2026 Autonomous racing

15% faster laps than standard MPC in a full-size race-car simulator

AD-MPCC: a racing controller that re-learns the road as it drives

It estimates tire–road grip online and retunes its own cost weights through a differentiable MPC, so it holds pace when the surface changes.
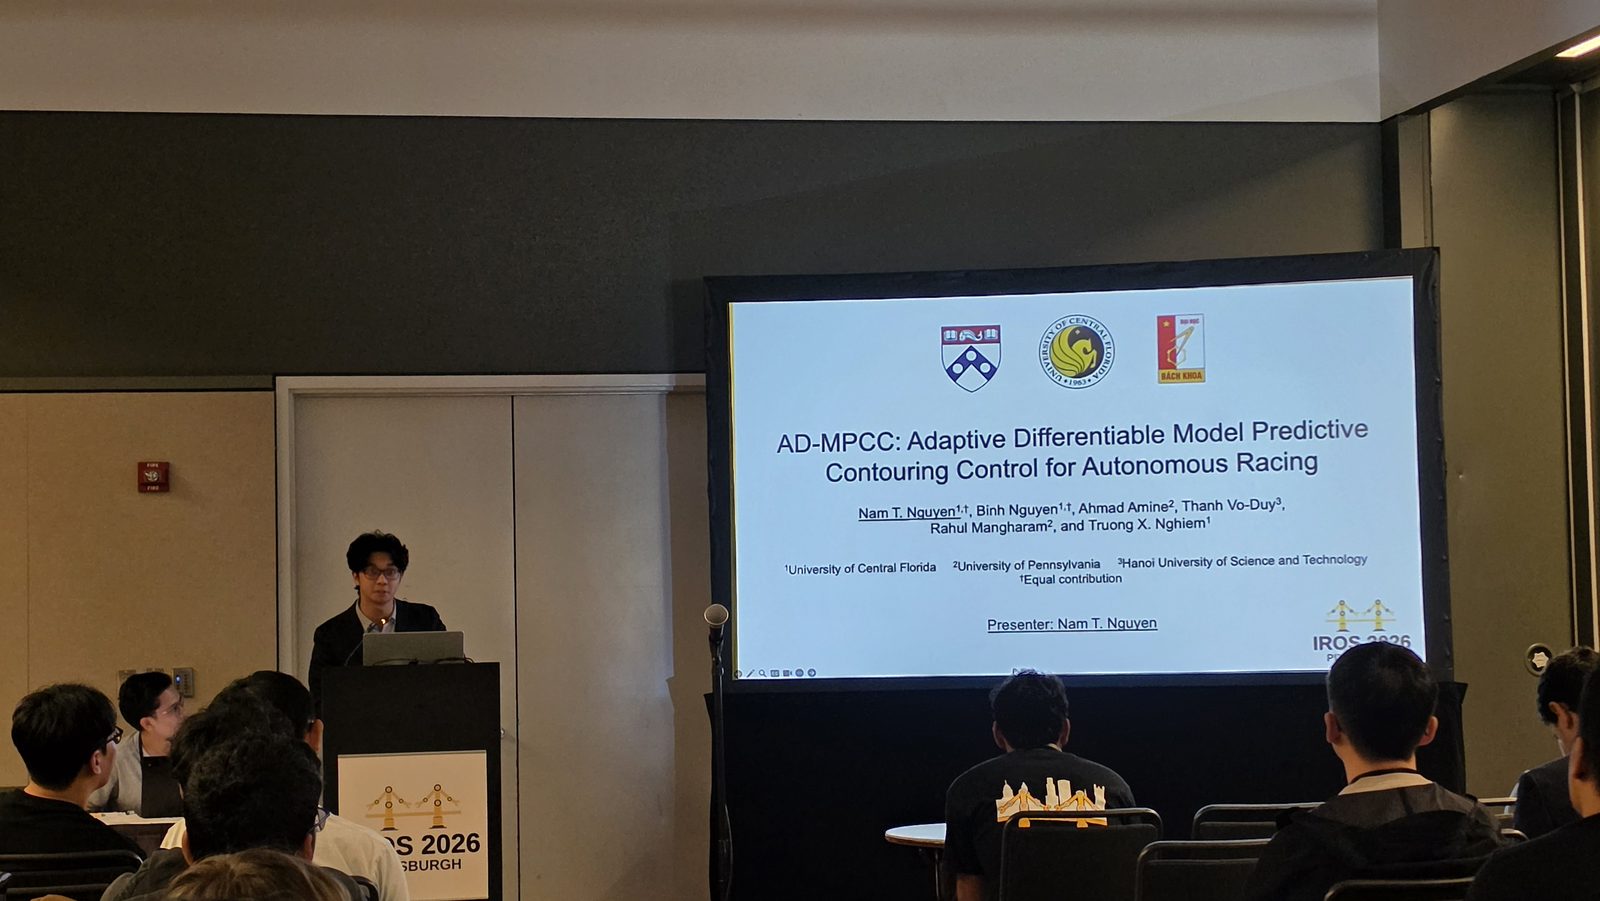
Nam Nguyen at the podium presenting the AD-MPCC paper at IROS 2026

IROS 2026 · PittsburghPresenting AD-MPCC

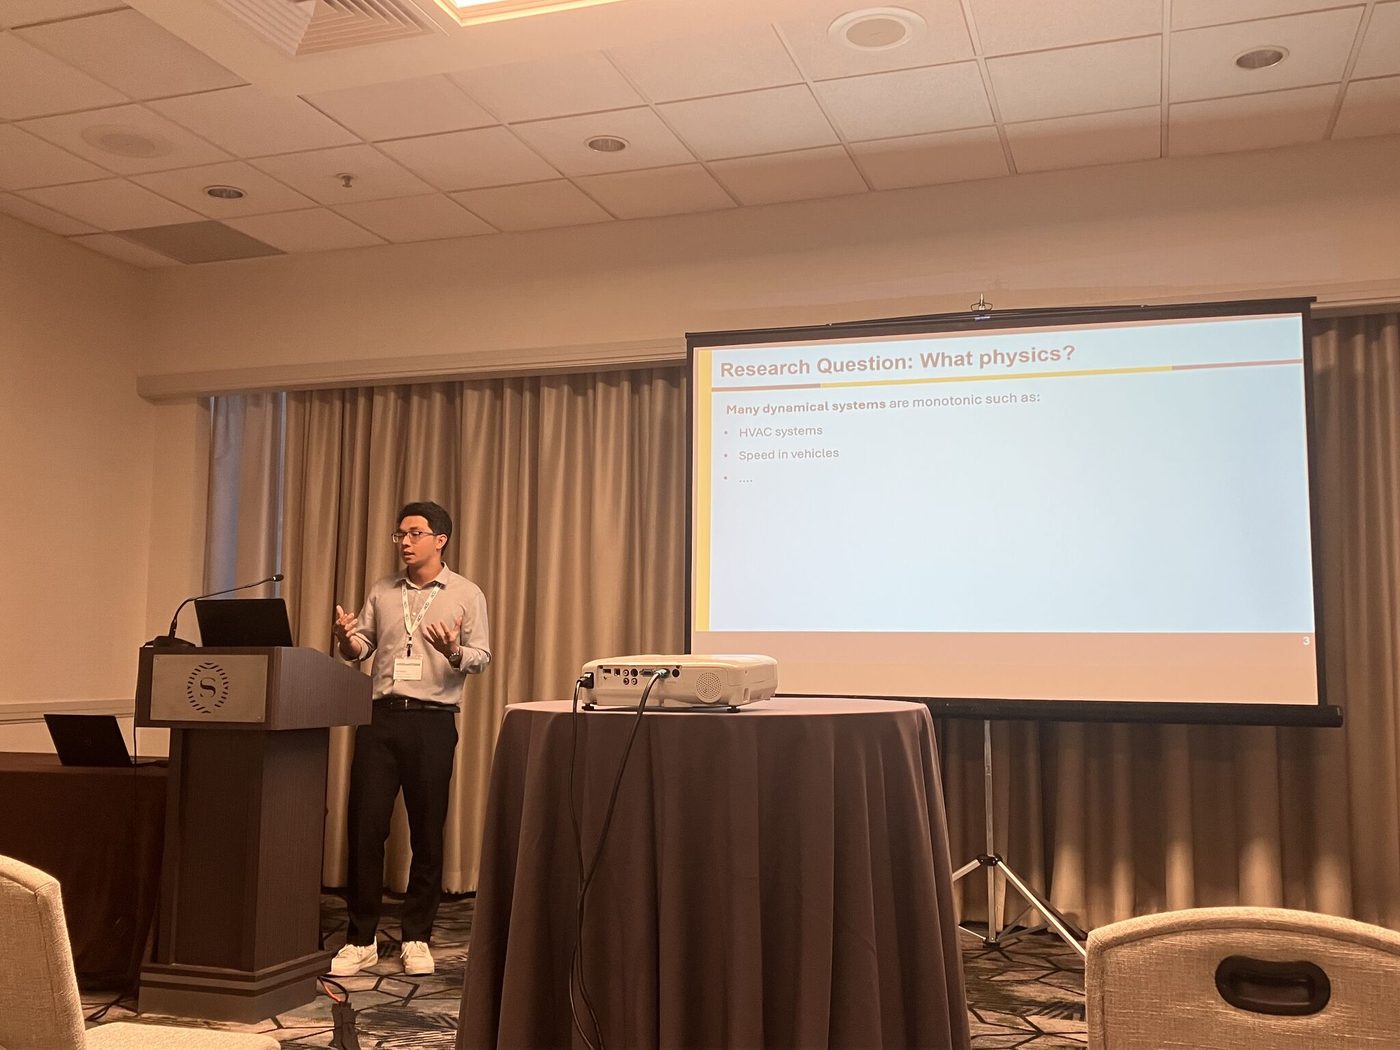
Nam Nguyen presenting the Taylor neural network paper at ACC 2025

ACC 2025 · DenverPresenting Taylor neural networks

ACC 2025

25% more accurate multi-step prediction than standard ML

Physics-constrained Taylor neural networks

A network that learns the derivative term of a Taylor expansion and keeps the system's monotonic behavior by construction.

HardwareArduino temperature-control lab, running MPC at 1°C steady-state error

IEEE Access 2026

13 modeling techniques compared on real-world HVAC data

Physics-informed modeling of HVAC systems

Physics-informed models beat physics-agnostic ones, most clearly when data is limited, unreliable, or noisy.

Beyond the lab

Teaching, building, and Research Talk

Teaching

From calculus tutoring to embedded systems

  • University of Central FloridaTeaching assistant, embedded systems on the TI MSP430 · 2026 – now
  • Northern Arizona UniversityTeaching assistant, Electronics and Signals & Systems · 2025
  • Hanoi Univ. of Science and TechnologyMath tutoring through the Learning Support Club

Hardware

Boards and rigs I've built on

  • TI MSP430Embedded systems course I TA at UCF
  • ArduinoMPC on a temperature-control lab
  • Raspberry Pi 4Person-following rover
  • NVIDIA JetsonReal-time vision at the edge
  • dSPACE DS1103 · TI C2000EV traction control, hardware-in-the-loop

Background

Education and contact

Contact

Get in touch

I'm open to internship conversations and research collaborations in machine learning, robotics, and control.

nam.nguyentran.ee2@gmail.com